
Faculty Research
Next-Generation Surgical Robotic Systems
Robotic-assisted surgery combines surgeon expertise with advanced robotic precision to improve patient care. In collaboration with Johns Hopkins University and UNCW’s Department of Psychology, we develop and evaluate shared-control systems that enable surgeons and autonomous robotic technologies to work together safely, effectively and seamlessly in the operating room.
Autonomous Foosball Table
The Autonomous Foosball Table serves as a hands-on research and teaching platform for Intelligent Systems Engineering. By integrating sensing, planning and control technologies into an engaging, game-based environment, the project gives students practical experience developing intelligent systems while exploring real-world challenges in robotics, automation and autonomous decision-making.
Gaze-Guided Teleoperation of Robotic Manipulators via Smart Glasses
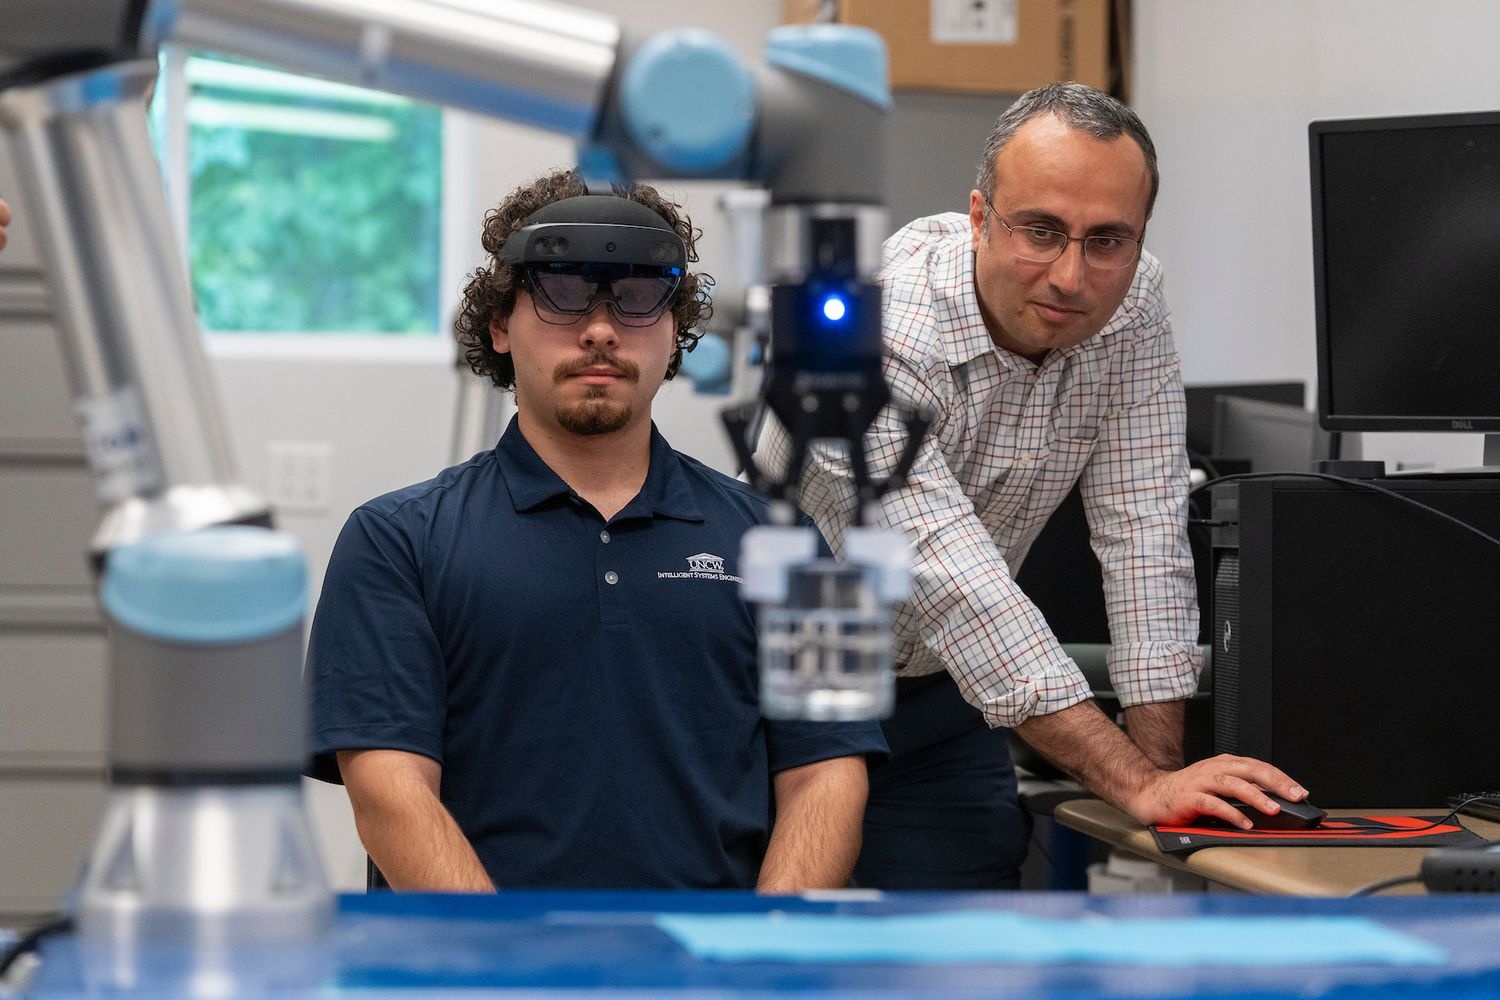
This project explores hands-free robot control using smart glasses and eye-tracking technology. Designed to support individuals with limited mobility, the system enables users to guide robotic manipulators through gaze alone. Our research develops advanced modeling, filtering and control strategies that make gaze-directed object manipulation accurate, intuitive and effective.




This project combines plant science with hands-on robotics to spark student curiosity in biology and engineering.
It also advances research in smart technologies like intelligent systems and the Internet of Things (IoT), such as sensors, machines, and everyday objects—that are connected to the internet and collect, share, and act on data.


